


Quantity
Technical Specifications
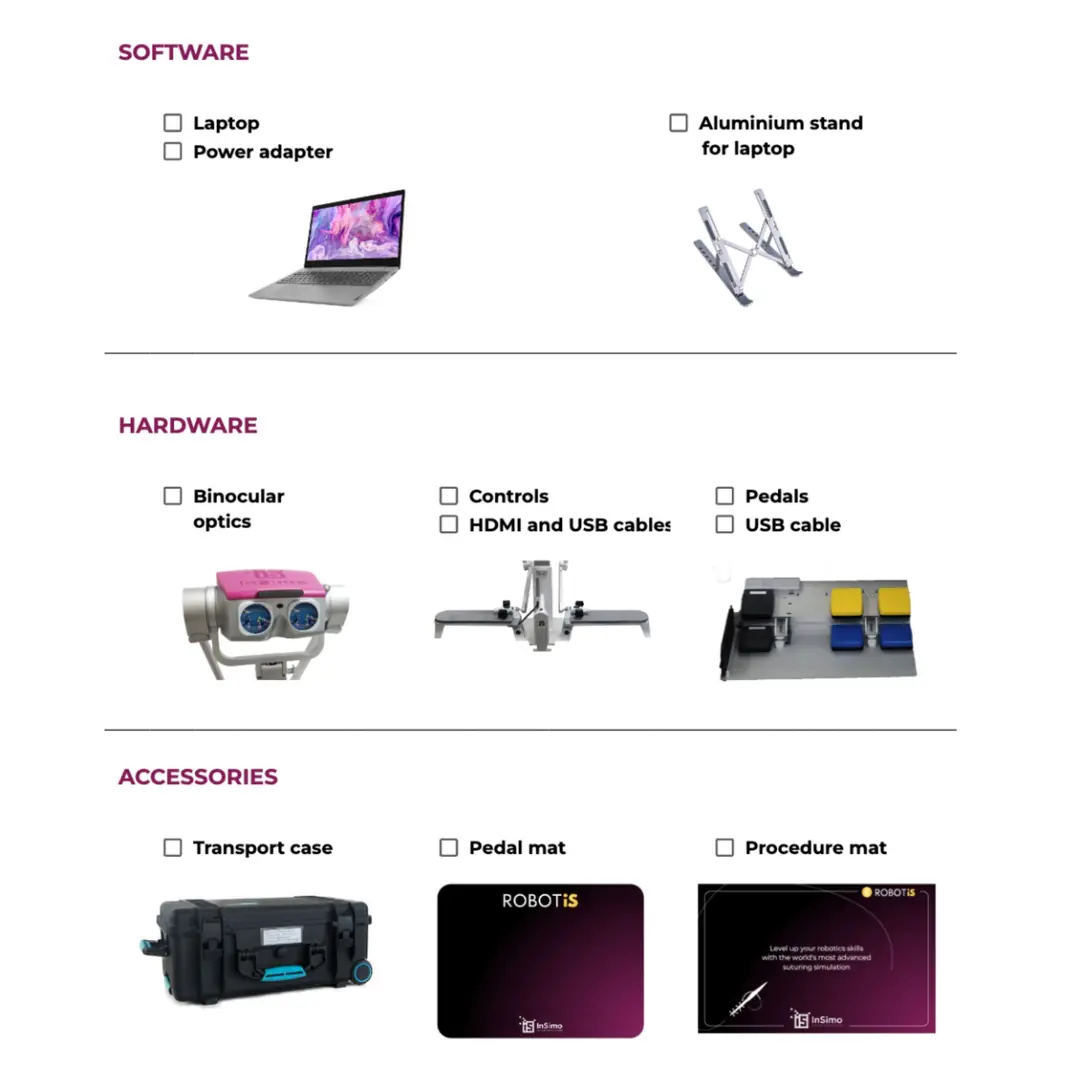
System Components
| TELEO Console Body | Vertical stand with an integrated desktop clamping mechanism. |
| Laptop | One laptop with sufficient performance to run the simulation software. |
| Binocular Optical Module | Head-mounted viewing unit providing stereoscopic 3D visualization. |
| Articulated Control Arms | Two instrument/control arms equipped with finger-trigger mechanisms. |
| Armrest Supports | Right and left arm supports designed for ergonomic operation. |
| Foot Pedal Unit | Multifunctional 7-pedal control unit with connection cables. |
| Transport Case | Compact, suitcase-style wheeled transport case designed to safely carry the complete system. |
| Laptop Stand | Aluminum laptop stand. |
| Pedal Mat | Non-slip mat for the foot pedal unit. |
| Work Mat | Protective mat for the work surface. |
| Laptop Carrying Case | Dedicated zippered laptop backpack. |
Computer & Hardware Technical Configuration
| Processor (CPU) | High-performance Intel Core i7 processor |
| Graphics Card (GPU) | NVIDIA RTX 5060 with 8 GB VRAM |
| Memory (RAM) | 32 GB |
| Storage | 1 TB SSD |
Dimensions & Workspace Requirements
| Weight | 18 kg |
| Package Dimensions | 67 × 44 × 54 cm |
| Minimum Worktable Dimensions | 60 × 120 × 75 cm |
| Chair | Height-adjustable, armless chair |
Training Content
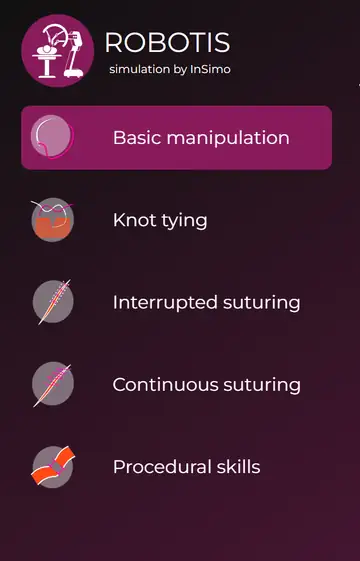
1. Basic Manipulation
| Peg Transfer | Object grasping, transfer, and placement exercise |
| Clutch Control | Positioning, clutching, and instrument repositioning control |
| Trajectory Control | Trajectory tracking and movement control |
| 3rd Instrument Control | Third instrument/arm control |
| Camera Control | Camera angle and field-of-view control |
2. Knot Tying
| Needle Driving | Guided Needle Passing |
| Assisted Needle Holding | Half Knot, Square Knot, Surgeon's Knot |
| Assisted Thread Holding | Half Knot, Square Knot, Surgeon's Knot |
| Freehand Tying | Half Knot, Square Knot, Surgeon's Knot |
| Surface Practice | Surface Half Knot, Surface Surgeon's Knot |
3. Interrupted Suturing
Single Thread
- Forehand Vertical Suturing
- Forehand Oblique Suturing
- Backhand Oblique Suturing
- Backhand Horizontal Suturing
Free Practice / Other Variations
- Forehand Vertical Suturing
- Forehand Oblique Suturing
- Backhand Oblique Suturing
- Backhand Horizontal Suturing
4. Continuous Suturing
Barbed Suture: Needle Driving
5. Procedural Skills & Anastomosis
| Procedures | Ventral Hernia Repair, Vaginal Cuff Closure |
| Anastomosis Modules | Vertical Anastomosis, Horizontal Anastomosis |
ROBOTiS – Portable Robotic Surgery Training Simulator
Shape the Surgical Skills of the Future Today
ROBOTiS is a next-generation, high-fidelity robotic surgery training simulator developed by InSimo to replicate the ergonomics, precision, and control experience of leading robotic surgical systems.
Designed for surgeons, surgical residents, and medical students, ROBOTiS provides a safe, repeatable, and measurable training environment for developing both fundamental and advanced robotic surgery skills.
With its portable and compact design, ROBOTiS makes high-quality robotic surgery simulation accessible across hospitals, universities, simulation centers, and surgical training programs.
Offered by PraticMed, ROBOTiS combines realistic robotic interaction with structured simulation exercises to support effective, hands-on robotic surgery training.

Contact For Online Demo
If you want to demo for Robotic Surgery Simulator, "Contact Us" You can send it to us by filling out the form.
We will evaluate and get back to you as soon as possible.